SEOK AutomotiveROBO LABROBOT DESIGN & HUMAN EXPERIENCE

INDEPENDENT STUDIO / GIMPO, KOREA

Open for project enquiries

FORM. MOTION.
CONNECTION.

Robot design. Exterior styling. Human-robot experience.
Shaping how robots look, move and respond.

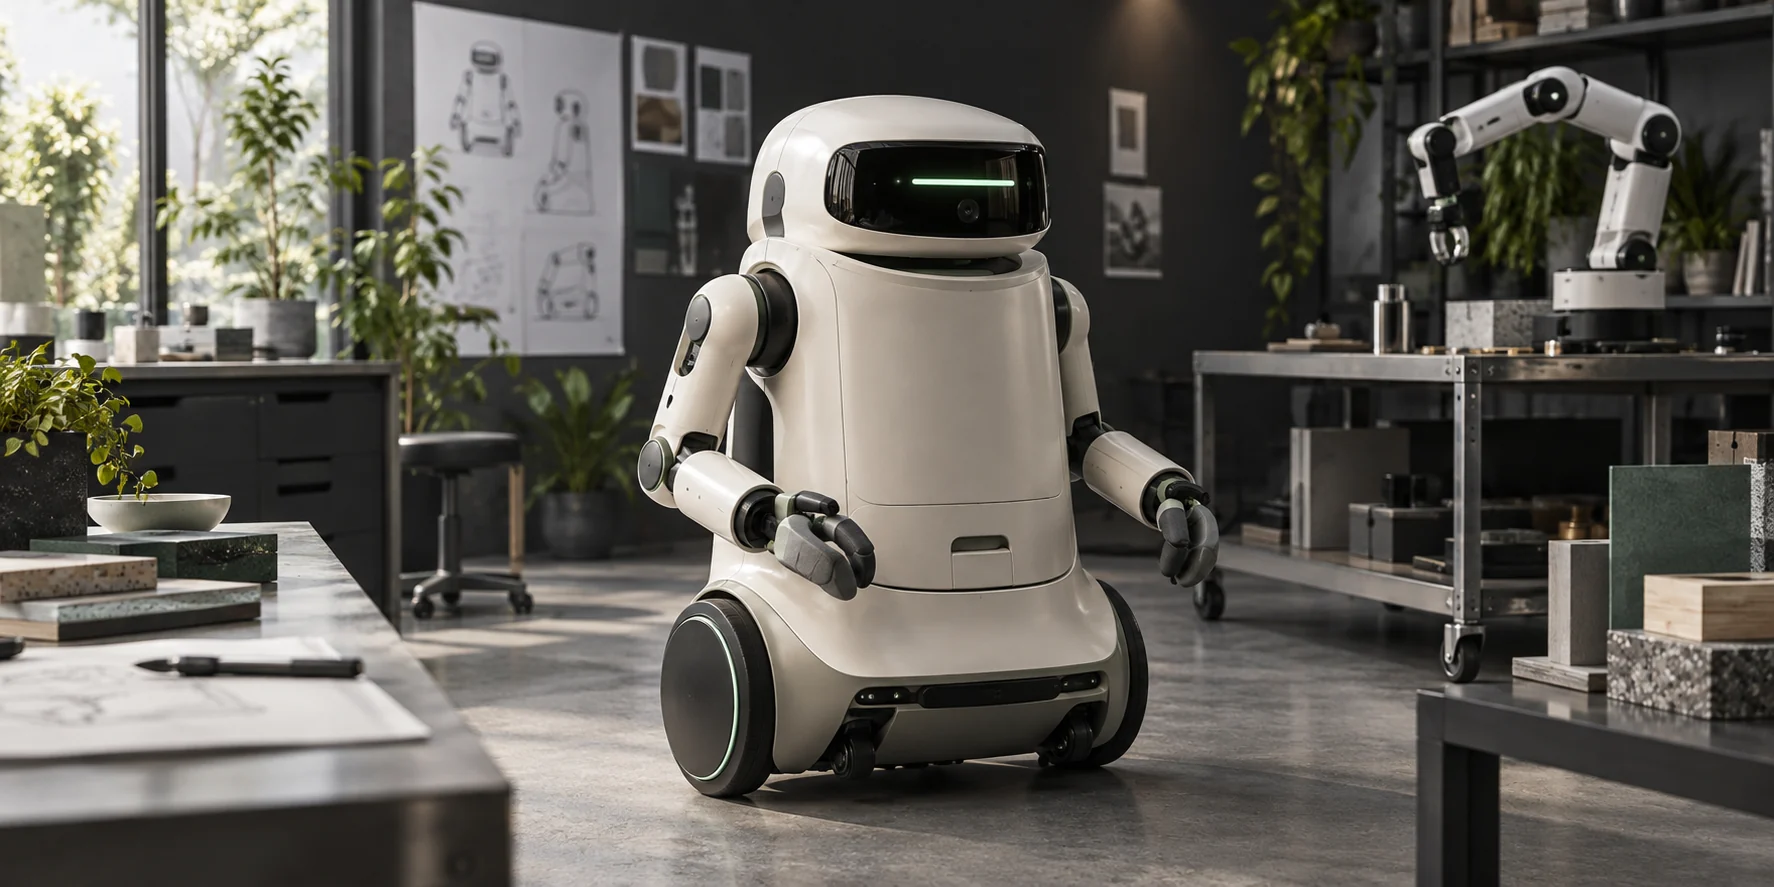
Home-assistance robot concept with an ivory body, articulated arms and a green status light in a design studio
01 / ROBOT FORM & CHARACTERSTUDIO CONCEPT VISUALIZATION

ENGINEERED TO ACT.
DESIGNED TO
CONNECT.

A robot is more than a mechanism. It has a presence, a purpose and a way of meeting people.

SEOK ROBO LAB is an independent robot design studio founded by a designer with robot design experience at Hyundai and Kia. We bring an automotive understanding of proportion, surfaces, packaging and human use to a new generation of robots.

We take on robot design, exterior styling and the complete interaction concept: physical form, movement, voice, expression and response. Digital development and hands-on mockups help teams review the robot as a product and as an experience.

Bring us your robot brief
ROBOT DESIGNPHYSICAL PROTOTYPINGHUMAN-ROBOT UX

AT WORK.
AT HOME.
WITH PEOPLE.

Design support across robot categories, from an early product concept to defined surfaces, mockups and interaction specifications.

01 / WEARABLE ROBOTICS

Factory wearable robots

Design development for industrial exoskeletons and wearable assistance systems. We study body fit, donning and removal, movement clearance, weight distribution and the appearance of the robot around the person.

02 / DOMESTIC ROBOTICS

Home & service robots

Approachable robots for everyday environments. We shape product architecture, exterior surfaces, touchpoints and interaction cues so that a robot’s purpose and state are easy to understand.

03 / INDUSTRIAL ROBOTICS

Industrial robots

Design for factory and professional settings, including collaborative robots, mobile platforms and task-specific systems. Covers, interfaces, access points and visual communication are developed around the engineering brief.

04 / ADULT COMPANION ROBOTICS

Companion & intimacy robots

Design development for adult companion and sex robots: physical form, materials, voice, personality and responsive behaviour. Interaction concepts address privacy, clear consent, personal boundaries and user control.

Each programme defines the intended users, operating context, engineering interfaces and deliverables. Design scope and prototype methods are agreed for the project.
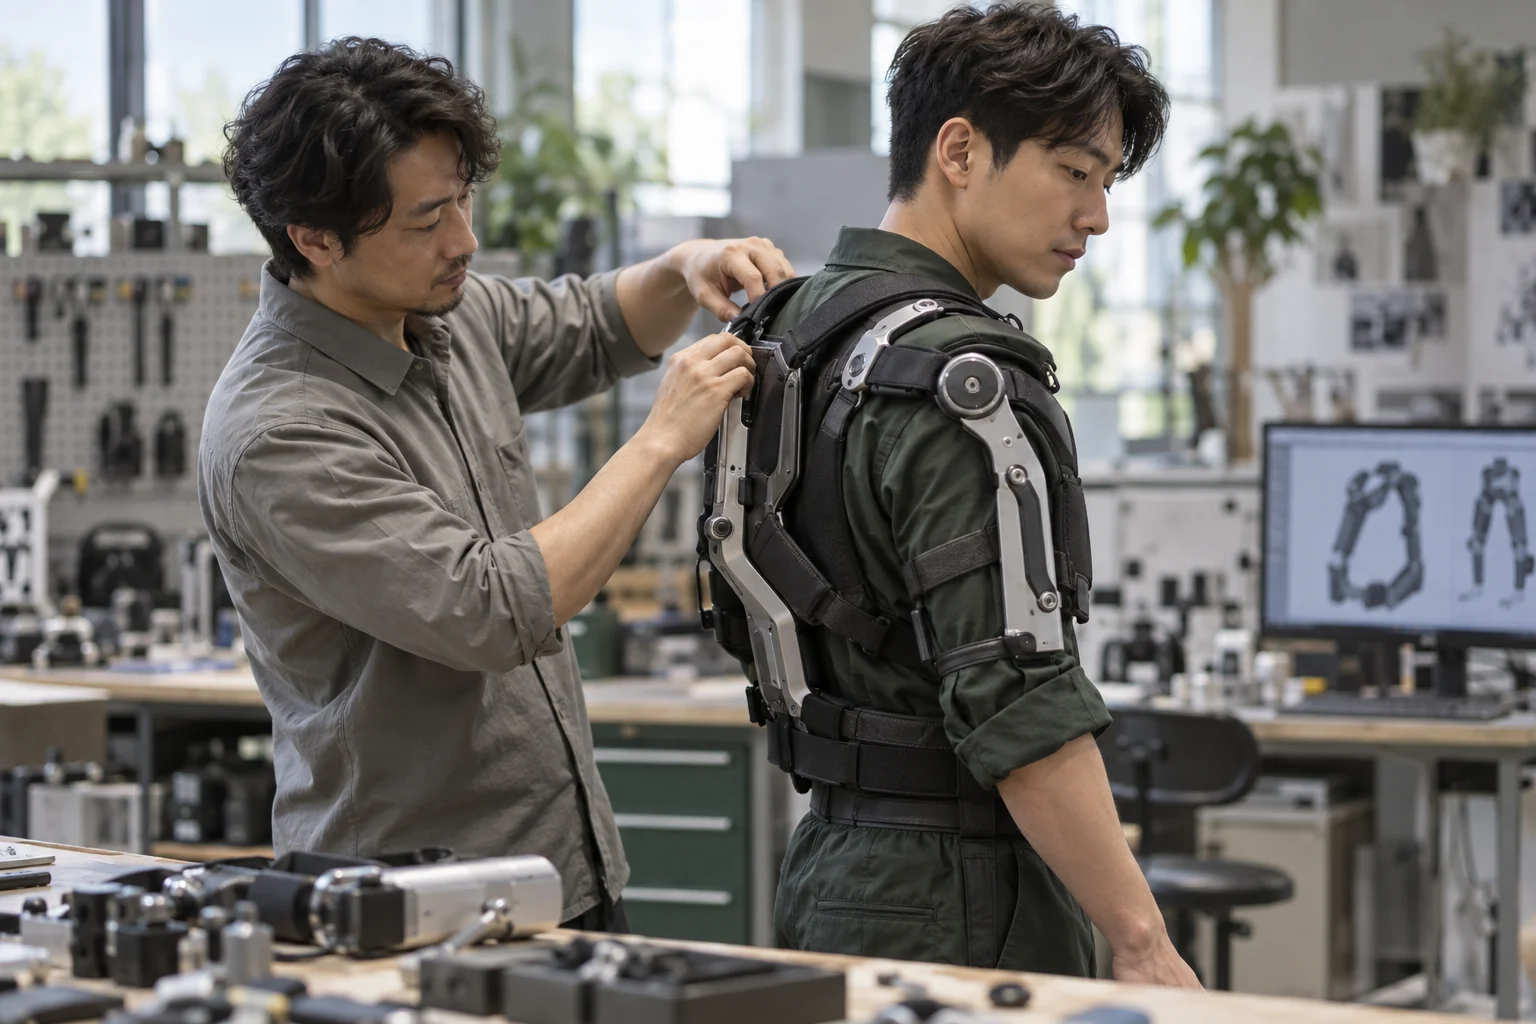
Concept visualization of a designer reviewing the fit of a shoulder-assist exoskeleton with an adult workshop operator
02 / WEARABLE ROBOT FIT REVIEW · CONCEPT VISUALIZATION

FROM DIGITAL FORM TO PHYSICAL FEEDBACK

DESIGN THAT
WORKS AROUND
THE HUMAN.

A wearable robot is experienced through every contact point. A physical mockup makes fit, reach, volume and movement easier to discuss than a screen alone.

We build and refine appearance models, ergonomic mockups and interaction prototypes, bringing the design back to the person who will use it.

Explore a prototype programme

MORE THAN
AN OUTER SHELL.

We design how a robot introduces itself, signals intent, listens and responds. Every channel should feel like the same character.

01 / PRESENCE

Form & expression

Proportion, posture, face architecture, light and display cues. A clear visual identity, from across a room to a close interaction.

02 / VOICE

Sound & personality

Voice character, language style, tone, pacing and non-verbal sound. Conversation flows that suit the robot’s role and the user’s context.

03 / MOVEMENT

Motion & gesture

Movement character, gaze direction, approach distance and gesture timing. Behaviour concepts developed with the controls and engineering teams.

04 / RESPONSE

Feedback & control

Touch, acknowledgement, state changes and recovery when something goes wrong. Clear ways to pause, decline, interrupt and regain control.

Typical outputs include robot character guidelines, interaction storyboards, voice and sound briefs, behaviour state maps and prototypes for user review.

DEFINE.
MAKE. REFINE.

A collaborative design process that keeps the physical product and the human experience moving together.

  1. 01

    Frame the purpose

    Define users, tasks, environments, engineering constraints and the intended character of the robot.

  2. 02

    Shape the concept

    Explore packaging, proportion and surfaces alongside voice, movement and interaction scenarios.

  3. 03

    Prototype & review

    Use digital models, physical mockups and behaviour prototypes to review the experience with your team.

  4. 04

    Resolve & deliver

    Refine agreed feedback and hand over the scoped CAD data, models and interaction documentation.

WHAT WILL
YOUR ROBOT
MAKE POSSIBLE?

Tell us who it is for, what it needs to do
and where you are in development.

Email your project brief

Start with a non-confidential overview. We can discuss an NDA before exchanging technical details.

PROJECT ENQUIRIES

VISIT BY APPOINTMENT

Gimpo Hangang Duclass
Units 522 & 523
362, Gimpohangang 2-ro, Gimpo-si,
Gyeonggi-do, Republic of Korea, 10081

FAX

+82-31-5186-0884

A HELPFUL STARTING BRIEF

Robot category · Intended users · Key tasks
Development stage · Design and UX scope · Timing